Programming and software
How a robot's behaviour is programmed for an event
· 4 min read

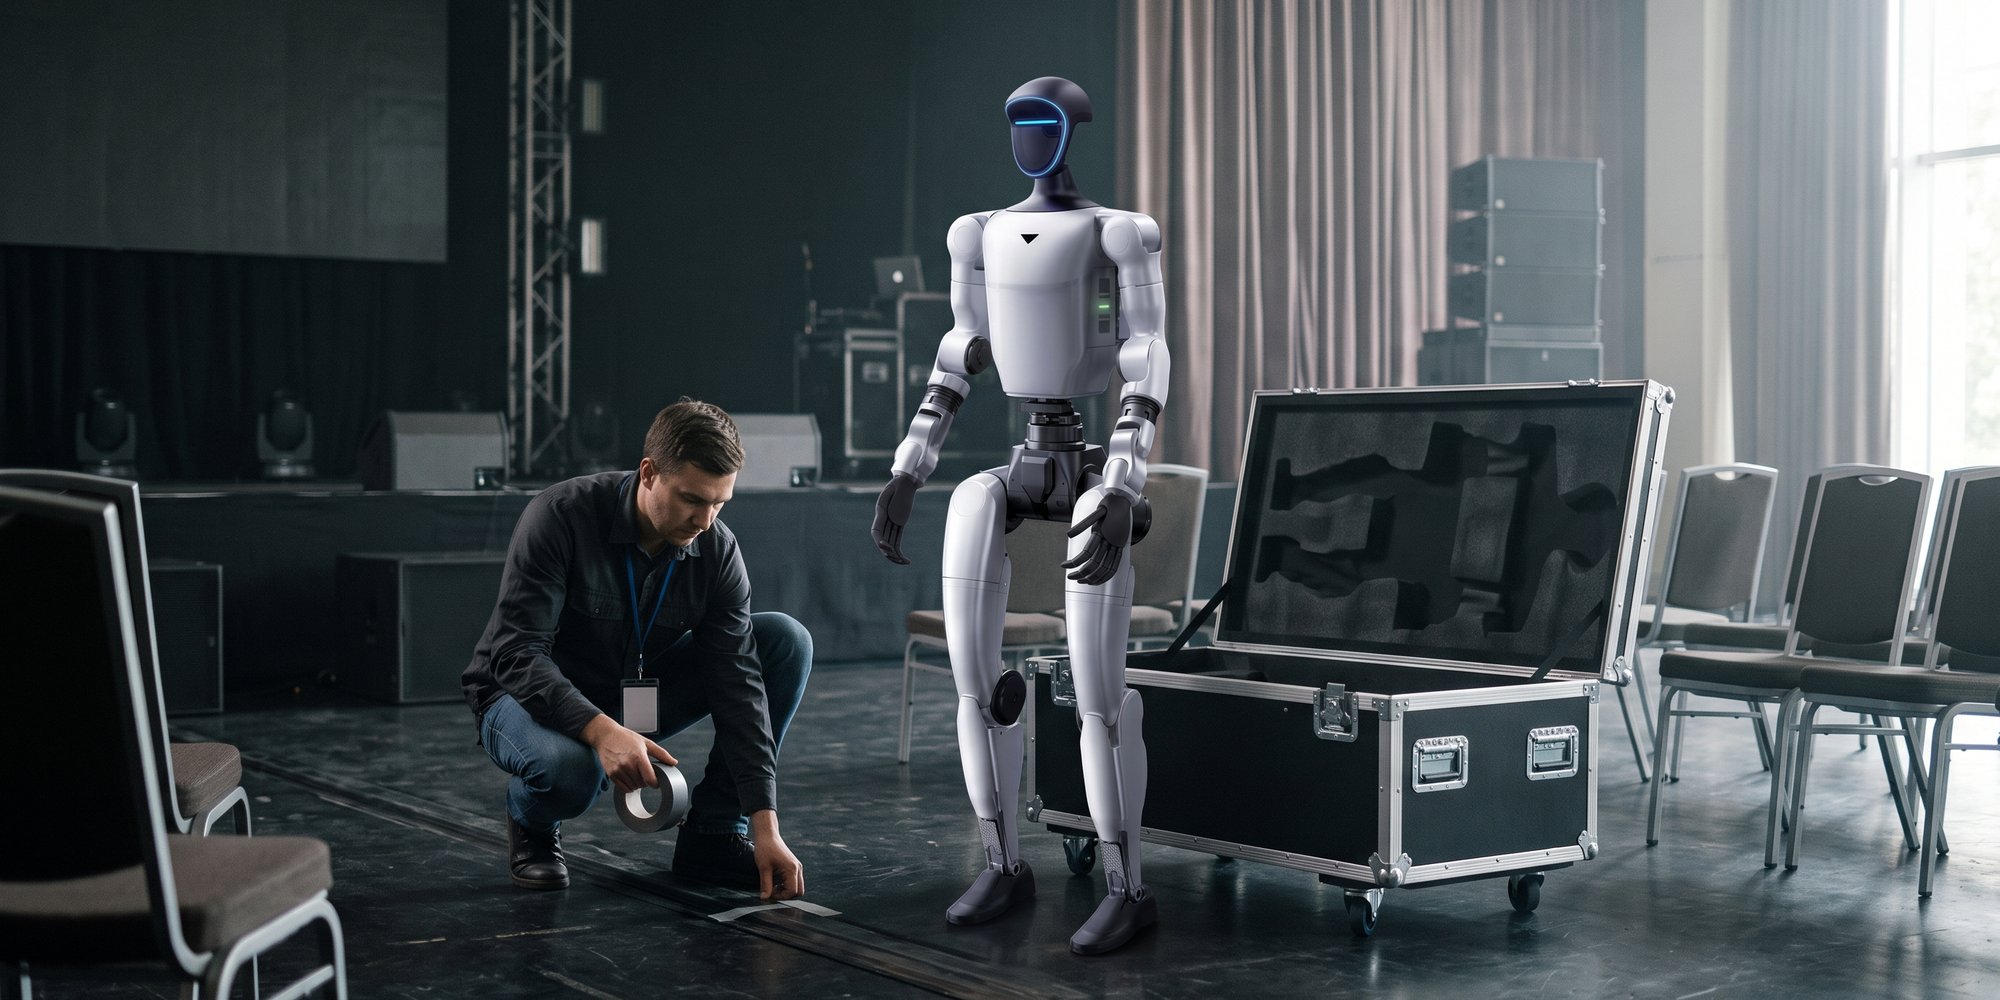
When a humanoid robot waves to visitors at an event, dances or responds to the host, it looks like magic. In reality there is a structured preparation process behind it that combines a script, motion programming, remote control and honest testing. In this article we look at how a robot's behaviour for an event is actually prepared and what to watch out for so the result works without a hitch.
Why the robot's behaviour has to be prepared in advance
A humanoid robot is not an actor who gets a script and improvises. Every movement, gesture and reaction has to be either programmed as a sequence or controlled by an operator in real time. Without preparation the robot at an event would either do nothing or react unpredictably, which is unacceptable for a machine moving among people.
The goal of preparation is therefore to design behaviour that is attractive to the audience, aligned with the event programme and safe at the same time. At its core this process is software and choreography work, and it is worth understanding before you book a robot for a specific scenario.
Step 1: the script and the goals of the activation
Programming never starts with code but with a script. First you need to know what the robot is supposed to achieve at the event. Different behaviour suits welcoming guests at the entrance, a product launch or an educational demonstration at a school.
In this phase we define specific moments: when the robot enters, what it does, how it responds to the host and how the scene ends. A good script shows how many movements need to be prepared and how much room we leave for live teleoperation.
- Goal of the activation: attention, a wow moment, education or content for social media.
- Key moments: entrance, interaction with the host, peak of the scene, ending.
- Space and audience: distance from people, movement path, lighting and sound.
- Timing: how long the robot performs and how it fits into the event programme.
Step 2: SDK, movements and choreographies
The technical foundation is the manufacturer's SDK. For Unitree robots (the MONTARI and NOVA models) an official SDK is available with a Python and C++ interface and ROS2 support. These tools give access to motor control, sensor readings and the launching of motion sequences.
The lower body of a humanoid usually has a built-in locomotion controller that takes care of balance and dynamic walking. The programmer therefore does not have to handle every step from scratch but composes higher-level logic: when the robot steps forward, turns, waves or starts a specific choreography. For the upper body and the dexterous hands, custom gestures and sequences are prepared.
From these building blocks a library of behaviours for the specific event is created: a greeting, a presentation gesture, a dance, a reaction to applause. These sequences can be triggered on command during the event.
Step 3: teleoperation versus autonomous sequences
At a real event two modes are almost always combined. Pre-prepared autonomous sequences ensure precise and repeatable moments, for example the entrance and the choreography. Teleoperation, meaning remote control by an operator, provides the flexibility to respond to the live situation, to the host's questions or to the movement of the audience.
This hybrid approach is the reason why a humanoid robot at an event always needs an operator. It is not a weakness but a standard that guarantees the robot does exactly what is needed, at the right moment and safely.
- Autonomous sequences: repeatable, precise, ideal for choreographies and entrances.
- Teleoperation: flexible response to the live situation and interaction with people.
- Safety logic: immediate stop and control of the movement path.
- Backup: a prepared plan B in case the event programme changes.
Step 4: testing and the limits of preparation
No behaviour is deployed live without testing. Before the event the sequences are rehearsed in conditions as close to reality as possible: on a similar surface, in similar lighting and with real timing. It is testing that reveals the small errors that would spoil the impression on the day.
The limits also need to be taken into account. Preparing non-trivial custom behaviour takes time, so complex scenarios are booked well in advance. The robot has limited battery life, so the length of the performance needs to be planned realistically. And the more new, untested logic there is, the more room for errors, which is why proven building blocks are preferred over live experiments.
For projects that go beyond an event, for example developing custom AI integrations or long-term testing, we offer development rental. There it makes sense to work with the EDU version (the NOVA model), which has full SDK access and more computing power.
Recommendation: what to prepare before ordering
If you are planning a robot for an event with specific behaviour, a clear script and enough lead time help the most. The sooner we know what the robot should do, the better we can prepare the sequences and test them. We have standard presentation behaviour and standard choreographies ready, so simpler events can be deployed quickly.
The price of an event rental depends on the length of the event, the robot model and the staging, development rental is priced individually, always plus a refundable deposit. If you have a specific scenario or an idea for an activation, write to us at info@robotrental.sk and within 24 hours we will prepare a feasible solution and a no-obligation quote.